- Gifts & Party Decorations
- Phone Accessories
- Photo & Video
- Computers & Electronics
- Sports & Fitness
- Beauty & Health
- Car & Motorcycle Accessories
- Bicycle Accessories
- Home & Living
- Garden & Outdoor
- Baby & Kids Products
- Games, Hobbies & Leisure
- Travel & Outdoor Activities
- Pet Supplies
- Discounted Items & Products with Defects
UNITREE G1 Dex3-1 Robotic Hands L+R with Tactile Sensors DEX3WT-214T
Unitree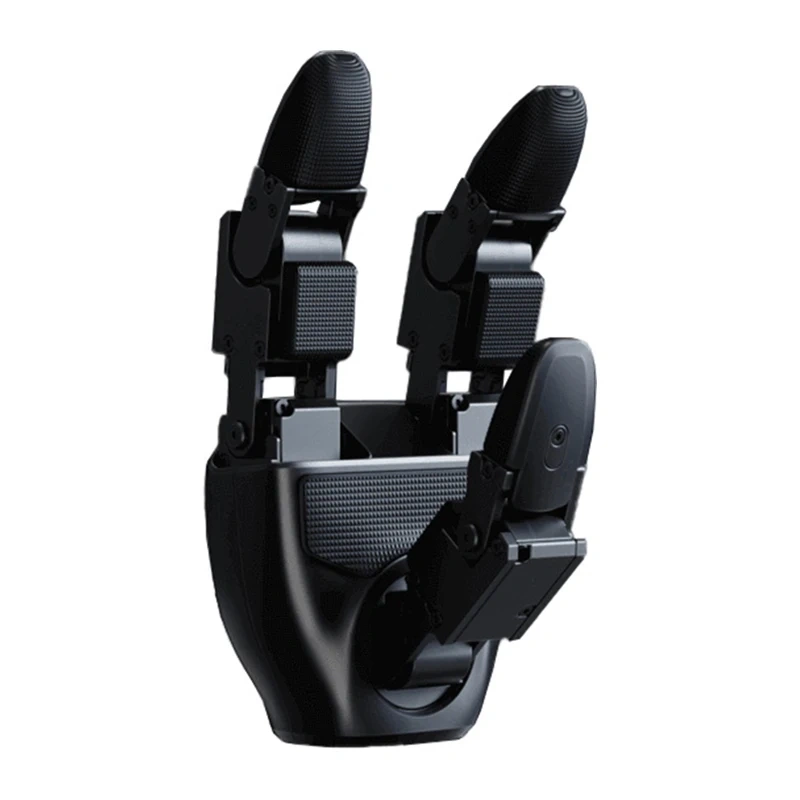
| Products ID: | 195429 |
|---|---|
| Manufactured by: | Unitree |
| Availablity: | Ready to Order |
| Delivery Time | 5-12 business days |
| EAN: | 5905156112063 |
Delivery options to:
LatviaThe UNITREE G1 Dex3-1 set includes left and right three-fingered robotic hands designed to work with the UNITREE G1 humanoid robot. Each hand provides 7 degrees of freedom, utilizes 7 miniature brushless force-controlled joints, and is equipped with 33 pressure sensors distributed across the palm, fingers, and fingertips.
Precise Movement and Tactile Sensing
Hybrid force- and position-based control enables precise regulation of movement and contact with handled objects, offering fingertip positioning repeatability of ±2 mm. The pressure sensors detect forces ranging from 10 g to 2,500 g, with a maximum non-destructive load tolerance of up to 20 kg.
Control and Real-Time Telemetry
Communication operates over a USB 2.0 interface at 1,000 Hz, with High Speed Unibus used for joint control. The system provides real-time feedback data including joint mode, position, velocity, torque, temperature, current, voltage, sensor pressures, and IMU data.
| Manufacturer | UNITREE |
|---|---|
| Model | DEX3WT-214T |
| Compatibility | UNITREE G1 |
| Hand weight | 710 g |
| Hand dimensions (when extended) | 175 × 88 × 77 mm |
| Degrees of freedom | Thumb ×3, index finger ×2, middle finger ×2 |
| Drive mechanism | 6 direct-drive motors, 1 gear-driven motor |
| Joint range of motion | Thumb joint 0: -60° to 60°; thumb joint 1: -35° to 60°; thumb joint 2: 0° to 100°; index finger joint 0: 0° to 90°; index finger joint 1: 0° to 100°; middle finger joint 0: 0° to 90°; middle finger joint 1: 0° to 100° |
| Fingertip positioning repeatability | ±2 mm |
| Operating voltage | 12–58 V |
| Standby current | 0.2 A at 58 V |
| Maximum current | 10 A |
| Communication interface | USB 2.0 |
| Operating temperature range | From -20°C to 60°C |
| Load conditions (palm facing down) | Maximum weight: 500 g; maximum power: 400 W for 3 s |
| Load conditions (palm facing left) | Maximum weight: 500 g; maximum power: 400 W for 3 s |
| Number of sensor arrays | 9 (33 pressure sensors in total) |
| Sensor array resolution | 2 × 2 (palm area) ×3, 2 × 2 (finger pad) × 3, 3 × 1 (single fingertip) × 3 |
| Detection range | 10–2 500 g |
| Maximum load without damage | 20 kg |
| Communication frequency | 1000 Hz |
| Full data packet size | Transmitter: 1234 bytes; receiver: 1270 bytes |
| Measurement feedback data | Joint mode, joint position, joint speed, joint torque, joint temperature, voltage and current, sensor pressure value, sensor temperature, IMU data |
| Control feedback | Joint mode, joint position, joint speed, joint torque, joint stiffness coefficient, joint damping coefficient |
| Joint motor model | F-1515-108 and F-1515-214 |
| Joint motor weight | 45 g |
| Joint motor dimensions | 34.8 × 23.1 × 23.3 mm |
| Joint gear ratio | F-1515-108: 1:108; F-1515-214: 1:214 |
| Theoretical maximum torque | F-1515-108: 0.76 Nm; F-1515-214: 1.498 Nm |
| Actual torque in direction of rotation | F-1515-108: 0.49 Nm; F-1515-214: 0.86 Nm |
| Actual torque opposite to direction of rotation | F-1515-108: 1.37 Nm; F-1515-214: 3.1 Nm |
| Maximum rotational speed | F-1515-108: 23 rad/s; F-1515-214: 11 rad/s |
| Joint maximum line current | 4.76 A |
| Joint communication method | High Speed Unibus |
| Encoder | Absolute rotor position encoder |
| Joint operating voltage | 12–24 V |
Which robot are the Dex3-1 robotic hands designed for?
These hands are designed specifically for use with the UNITREE G1 humanoid robot.
How many tactile sensors are integrated into each hand?
Each hand contains 9 sensor arrays with a total of 33 pressure sensors across the palm, fingers, and fingertips.